Archives

ECE Seminar Series: Large-Area High-Efficiency Solid-State Thermal Neutron Detector

ECE title

ECE Seminar Series Spring 2016

Thursday May 5th 1-2 PM, ITEB 336

Large-Area High-Efficiency Solid-State Thermal Neutron Detector

Rajendra Dahal

Electrical, Computer, and Systems Engineering

Rensselaer Polytechnic Institute, Troy, New York

Abstract: The development of high-efficiency large-area solid-state neutron detectors is urgent for a wide range of civilian and defense applications; such as monitoring of “dirty bombs”, border patrol, medical and industrial imaging. The applications of present neutron detector systems are limited by cost, size, weight, and power requirements. An efficient self-powered, or low-power, solid-state neutron detector using mature silicon technology would provide significant benefits in terms of cost and volume. Also, it would allow wafer-level integration with readout electronics. This talk presents current research advances on fabrication and characterization of a large area solid-state thermal-neutron detector module with detection efficiency exceeding 30%. The detector utilizes three-dimensional honeycomb silicon microstructures, and a continuous p+-n junction diode filled with enriched boron (99% of 10B) as a converter material for thermal-neutron detection. The low leakage current density of the fabricated device helps to increase the detector surface area to greater than 16cm2. These results show promise in using such highly efficient large-area solid-state neutron detectors in home land security applications.


Short Bio: Dr. Rajendra Dahal is a Research Assistant Professor in the Electrical, Computer, and Systems Engineering Department here at Rensselaer. His current research interests include epitaxial growth of wide band-gap semiconductor thin films, such as 2D layered materials and nanostructures; fabrication of micro/nanostructures for efficient radiation detectors; and optoelectronic devices.
 

ECE Seminar Series: Industrial Strength Real World Multi-Sensor Data Fusion

ECE title

ECE Seminar Series Spring 2016

Monday May 2rd 1-2 PM, ITEB 336

Industrial Strength Real World Multi-Sensor Data Fusion

Frederick E. Daum

Raytheon

Abstract: We explain why multi-sensor data fusion is a difficult problem in the real world. We also describe several new algorithms that are designed to solve such problems, considering real world effects. The major real world issues for data fusion include: (1) unresolved sensor data; (2) residual sensor bias errors; (3) closely spaced multiple targets; (4) unresolved sensor data; (5) non-unity probability of detection and non-zero probability of false alarms from noise & clutter; (6) inconsistent covariance matrices; and (7) unresolved sensor data. Such problems often result in putting the wrong data into your favorite estimation algorithm (extended Kalman filter, particle filter, unscented Kalman filter, etc.). The best way to ruin the performance of a good filter is to put the wrong data into it. One of the best algorithms to mitigate such problems is called GNPL (global nearest pattern Levedahl), invented at Raytheon. This algorithm jointly estimates the residual relative sensor biases and the association of data or tracks between sensors. The key word is “jointly”. We show comparisons of GNPL vs. simpler algorithms that decouple the bias estimation and data association problems. For difficult scenarios, GNPL is superior to simpler decoupled algorithms. We also describe more advanced algorithms that promise better performance at the cost of higher real time computational complexity. Such algorithms actually model the correct relevant physics, and they also exploit recent advances in particle filters and GPUs and the theory of random sets. This talk is for normal engineers who do not have nonlinear filters for breakfast.


Short Bio: Fred Daum is an IEEE Fellow, a principal Fellow at Raytheon, a Distinguished Lecturer for the IEEE and a graduate of Harvard University. Fred was awarded the Tom Phillips prize for technical excellence, in recognition of his ability to make complex radar systems work in the real World. He developed, analyzed and tested the real time algorithms for essentially all the large long range phased array radars built by the USA in the last four decades, including: Cobra Dane, PAVE PAWS, Cobra Judy, BMEWS, THAAD, ROTHR, UEWR, and SBX, as well as many other systems (SPY-3 proposal, JLENS proposal, SPACE FENCE proposal, LRDR proposal, JADGE, Project Hercules, ADI concept A, C-RAM, C-MAR, AN/TPN-19, ASDE-X, DERD-MC, NATO Sea Sparrow, DLGN-38, GPS OCX and several sonar systems). These real time algorithms include: extended Kalman filters, radar waveform scheduling, Bayesian discrimination, data association, discrimination of satellites from missiles, calibration of tropospheric and ionospheric refraction, and target object mapping. Fred’s exact fixed finite dimensional nonlinear filter theory generalizes the Kalman and Beneš filters. Fred’s particle flow nonlinear filter is many orders of magnitude faster than standard particle filters for the same accuracy. He has published nearly one hundred technical papers, and he has given invited lectures at MIT, Harvard, Yale, Caltech, the Technion, Ecole Normale Superieure de Paris, Brown, Georgia Tech., Duke, Univ. of Connecticut, Univ. of Minnesota, Melbourne Univ., Univ. of Toulouse, Univ. of New South Wales, Univ. of Canterbury, Liverpool Univ., Xidian Univ., Univ. of Illinois at Chicago, Washington Univ. at St Louis, McMaster Univ., Boston Univ., Northeastern University, Huntsville, Colorado and Rutgers.


International Conference on Complex Systems Engineering (ICCSE 2015) Held in UConn

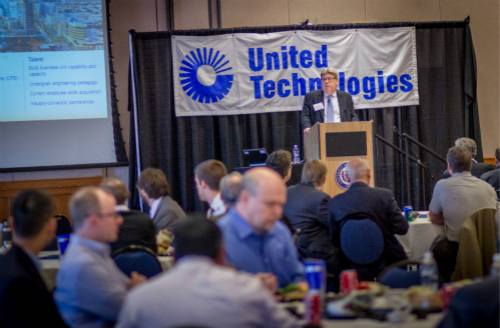
The University of Connecticut (UCONN) organized a two-day international conference on complex systems engineering (ICCSE 2015) on November 9-10, 2015 at the UConn’s main campus in Storrs, CT. The conference organization committee was led by Dr. Krishna Pattipati as the general chair and Dr. Shalabh Gupta as the program chair. The conference was focused on latest developments in analysis and modeling of complex systems that are built from, and depend upon, the synergy of computational and physical components, the so-called cyber physical systems. The conference featured talks by plenary speakers from industry and academia, panel discussions, technical paper sessions, student poster sessions and industry exhibits. The conference was a 2nd year initiative by the recently established UTC Institute for Advanced Systems Engineering (UTC-IASE). The conference was financially co-sponsored by UTC and Aptima and technically sponsored by IEEE-Systems Man and Cybernetics Society. The conference served one of the institute’s goals of making it a hub for world-class research, project-based learning by globally-distributed teams of researchers, and industrial outreach activities.UTCmeeting3_1

There were four plenary speakers, viz., Dr. Michael McQuade (Senior Vice President of Science and Technology at UTC), Dr. Edward Lee (Robert S. Pepper Distinguished Professor in the Electrical Engineering and Computer Sciences (EECS) department at U.C. Berkeley), Dr. George Pappas (Joseph Moore Professor in the Department of Electrical and Systems Engineering at the University of Pennsylvania), and Dr. Chris Paredis (Program Director for the Engineering and Systems Design (ESD) and Systems Science (SYS) programs at the National Science Foundation). Dr. Michael McQuade outlined the mega-trends that are impacting systems engineering and highlighted technology and talent needs of the industry and more specifically of UTC. Dr. Edward Lee provided an overview of the need for models with time and concurrency requirements, model-based design and analysis, domain-specific languages, architectures for real-time computing, schedulability analysis, and modeling and programming of distributed real-time systems. Dr. George Pappas gave a talk on formal synthesis and analysis for supervisory control of hierarchical hybrid systems using linear temporal logic. Dr. Chris Paredis spoke about the theoretical foundations for Systems Engineering, the role of modeling in Systems Engineering  and gave the audience a glimpse of opportunities for research in Systems Engineering and model based systems engineering (MBSE) being sponsored by NSF.

In addition to the plenary speakers, many representatives from industry and academia presented their latest research along three tracks of embedded systems, complex networked systems: control and inference, and model based systems engineering and applications. There was an education panel where educators from UConn, Stevens Institute of Technology, and Worcester Polytechnic Institute and UTC exchanged lessons learned and discussed the standardization of Systems Engineering education. The conference was truly international with representation from Asia, Europe and North America. More than 80 people participated in the conference which led to a healthy exchange of ideas. Planning for next year’s conference on the Avery Point campus of the University of Connecticut is already underway.


ECE Seminar Series: Enabling resilient control of power systems with distributed energy storage

ECE title

ECE Seminar Series Fall 2015

Monday November 16th 2-3 PM, ITEB 336

Enabling resilient control of power systems with distributed energy storage

Mads R. Almassalkhi

University of Vermont

Abstract: In 2003, the National Academy of Engineering named the electric grid the Greatest Engineering Achievement of the 20th century, however, just a few months later, US and Canada experienced their largest ever black-out. Year-to-year increases in the number of large blackouts suggest that power systems today are operated closer and closer to their limits. To aid human control-room operators overcome this challenge, increased sensing and actuation is becoming available in the control room, including PMUs, FACTS devices, and fast-acting demand and energy storage. However, this added system complexity makes it more difficult for human operators to determine an appropriate response to unanticipated events. At a minimum, decision-support tools are needed to guide human decision-making. In fact, closed-loop feedback processes will become indispensable. As such, we present resilient model predictive control (MPC) schemes that mitigate the effects of overloads in transmission and distribution systems. Resilient control is achieved through a receding-horizon model predictive control (MPC) strategy which alleviates temperature-based overloads on transmission lines and distribution-level transformers and, therefore, prevents large outages. Both centralized and distributed optimization-based schemes will be presented with numerical case studies.


Short Bio: Mads R. Almassalkhi is an Assistant Professor at School of Engineering at the University of Vermont. His research interests lie at the intersection of power systems, optimization, and controls and focus on developing novel feedback and optimization algorithms that improve responsiveness and resilience of power systems, which is increasingly more important as power systems are operating closer and closer to their limits. His past work includes model predictive control of bulk power systems, distributed control of multi-agent systems, applications of optimization and systems theory to electric and multi-energy power systems. Prior to joining the University of Vermont, he was lead systems engineer at Root3 Technologies. He received his MS and PhD from the University of Michigan in Electrical Engineering: Systems and a dual-degrees in Electrical Engineering and Applied Mathematics from the University of Cincinnati, Ohio.


ECE Seminar Series: The Emergence of Topological Insulators as Candidates for Optoelectronics and Spin-Based Applications

ECE title

ECE Seminar Series Fall 2015

Thursday November 13th 1-2 PM, ITEB 336

The Emergence of Topological Insulators as Candidates for Optoelectronics and Spin-Based Applications

Parijat Sengupta

Boston University

Abstract: The advent of topological ideas in condensed matter is a new paradigm where the traditional notions of Fermi-liquid theory and order parameter do not explain experimentally observed phenomena, for instance, the integer and fractional quantum Hall effect and the more recently discovered topological insulators (TI). In this presentation, I will focus on topological insulators and go over some of the key facts that typically characterize these materials. I will begin by presenting  analytic results on band structure of topological insulators derived using a simple Dirac Hamiltonian and connect them to more elaborate semi-empirical tight binding and continuum k.p calculations. An important aspect of TI band structure is the helical dispersion where the spin is locked perpendicularly to momentum giving rise to 1) spin-polarized photocurrents when the surface is illuminated with circularly-polarized light and 2) spin-dependent optical transition from valence to conduction surface bands. Using the phenomenon of circular dichroism (preferential absorption of right- or left-circularly polarized light), I will emphasize on light absorption on the surface of 3D TIs such as Bi2Se3 with a single Dirac cone and  contrast them with the C2v group symmetric (at X symmetry point) triple Dirac-coned topological Kondo insulator (TKI) samarium hexaboride (SmB6). I will explicitly show how the helical band structure of SmB6 at the X symmetry point of the surface Brillouin zone with Rashba- and Dresselhaus-like terms give rise to a dual-valued circular dichroism. Further, using the Berry curvature I will try to draw a parallel between the emerging field of valleytronics in transition metal dichalcogenides such as MoS2 and TIs that conform to the C2v symmetry. I will seek to emphasize that the strong polarization-dependent light absorbance on account of the Dirac fermions on surface of a TI and an easily tunable surface band gap can lead to design of optoelectronic devices with greater efficiency. Since spin and its myriad manifestations in solid state is crucial to topological insulators, I will present results on the frequency-dependent spin susceptibility in the TKI SmB6 which may prove useful to probe spin density currents that serve as the foundational block of spin-based applications. In the last part of the talk I will draw attention to the fact that while most topological insulators are strongly spin-orbit coupled driven, the multi-layered Dirac semi-metal black phosphorus which is a 2D material undergoes a giant Stark effect induced topological phase transition when doped with potassium. The topological features of BP with Dirac fermions and a linear band structure can lead to graphene-like transport properties for improved device performance. I will map the dynamic optical conductivity and spin current density changes to the transitions of BP from a trivial insulator with finite band gap to a zero gap material and then to a topological insulator with increasing dopant (K) density.


Short Bio: Parijat Sengupta received his PhD in electrical engineering from Purdue University, West Lafayette in December 2013 where he primarily worked on the electronic structure of materials and focused on topological insulators for his dissertation. Following his PhD, he joined the computational materials group at the University of Wisconsin-Madison, Madison in January 2014 as a postdoctoral research associate and was involved in modeling of defects in nuclear materials using ab-initio principles and molecular dynamics. He moved to the Photonics Center at Boston University in March of 2015 as a postdoctoral research associate and is currently working on light-matter interaction and spin transport in topological insulators and electron transport in colloidal quantum dots. Prior to joining Purdue university, he was employed with Nvidia Corp., Santa Clara as a product engineer.


ECE Seminar Series: Materials Under Extreme Electric Fields

ECE title

ECE Seminar Series Fall 2014

Thursday December 4th 1-2 PM, ITEB 336

Materials Under Extreme Electric Fields

Yang Cao

Electrical and Computer Engineering, University of Connecticut

Abstract: The rising demands for electrical power and miniaturization of electronic devices have at least one requirement in common, the ever thinner dielectrics operating under extreme electric fields. Despite the long history of engineering and fascinating failure patterns, the dielectric breakdown process and mechanism are actually poorly understood “to the extent that predictions of the breakdown strength of solids cannot be made solely on a molecular basis…. A theory for high-field conduction in solid insulation systems is at the root of such understanding, and no such theory exists at present[1]”. Combinatorial computational and experimental tools are under development for the fundamental understanding of critical prebreakdown processes such as charge injection, transport, trapping and defects creation that lead to instability under extreme electric fields. Recent progress in high field characterizations made in Rational Design of Advanced Polymeric Capacitor Films MURI Project and Polymeric HVDC Cabling project will be reported out to showcase the initial steps towards the predictive design and development of power components with game changing characteristics for power conversion and renewable integration.


Short Bio: Yang Cao is an associate professor at Electrical and Computer Engineering Department and the director of the Electrical Insulation Research Center (EIRC) of the University of Connecticut. After graduating from the University of Connecticut in 2002, he worked at GE Global Research Center as an electrical engineer for 11 years in the fields of high voltage engineering for electrical power and medical diagnosis imaging. At EIRC, he is currently conducting research projects funded by DOE, DOD, industrial corporations such as GE, Exxon-Mobile, Schlumberger, to develop enabling technologies for high renewable penetration.

当前显示image002.jpg当前显示image003.jpg


[1] DOE Basic Energy Sciences Workshop Report: Research Needs for Materials under Extreme Environments

ECE Seminar Series: Application-Specific HPC from an Operational Standpoint

ECE title

ECE Seminar Series Fall 2014

Thursday November 13st 1-2 PM, ITEB 336

Application-Specific HPC from an Operational Standpoint

Chris J. Michael

Naval Research Laboratory

Abstract: There are numerous situations, especially within the Department of Defense (DoD), where smaller HPC systems are specified and deployed to handle a moderately predictable workload containing less than a dozen or so special-purpose applications. Typically, these systems are designed in a naive way using rough high-level benchmarking and intuition. In most cases, this results in a system that runs the workload inefficiently, consuming precious resources and dramatically increasing the operational cost of the system.

Application-specific HPC involves designing heterogeneous systems with respect to the application workload. This is accomplished through profiling of the applications against the potential hardware candidates. Resulting systems can dramatically increase the workload efficiency when considering execution time, cost of operation, power, size, and weight. In this presentation, the basics of application-specific HPC from an operational DoD standpoint are covered. Additionally, case studies that exemplify this methodology are presented, the most thorough of which deals with all-pairs shortest paths processing for sparse graphs.


Short Bio: Dr. Chris J. Michael is a computer engineer with the Naval Research Laboratory located in Stennis Space Center, Mississippi. His research interests include heterogeneous computing, special-purpose computer architecture, large-volume streaming data processing, and high-performance image processing. Chris is currently working with Department of Defense sponsors to find rapidly transition able solutions to computationally heavy problems. Examples of involved computation of interest include graph processing such as centrality as well as image processing involving sparse representation theory. He received his doctorate in electrical engineering from Louisiana State University in 2010.


Host: Omer Khan, omer.khan@engr.uconn.edu

ECE Seminar Series: Passivity-Based Control and Estimation in Networked Robotics and Vision

ECE title

ECE Seminar Series Fall 2014

Thursday October 30st 1-2 PM, ITEB 336

Passivity-Based Control and Estimation in Networked Robotics and Vision

Takeshi Hatanaka

Assistant Professor, Department of Mechanical and Control Engineering, Tokyo Institute of Technology


Abstract: This talk introduces a series of our research outcomes on passivity-based
estimation and control in networked robotics and vision. The former part discusses how passivity is utilized for visual feedback motion estimation and control. After pointing out inherent passivity in 3-D rigid-body motion, we present a passivity-based 3-D motion estimation mechanism, termed visual motion observer, and the observer-based camera control scheme. It is also shown that the presented framework can successfully incorporate other passive components like an object motion model and a manipulator dynamics while ensuring stability of the total system, owing to passivity preservation property w.r.t. feedback connections. The second part investigates passivity-based cooperative control and estimation. We first introduce a basic idea of synchronizing passive dynamical components under local interactions. Based on the approach, we then address 3-D motion coordination problems
of a network of rigid bodies. The presented results are also extended to flocking in three dimensions,
making use of the energy-based property of the passivity approach. Finally, we address visual feedback motion coordination and cooperative motion estimation, combining the ideas of the above two parts.
A book compiling the contents of this talk will be published in 2015 (expected).


Short Bio: Takeshi Hatanaka received B.Eng. degree in informatics and mathematical science, M.Inf.
and Ph.D. degrees in applied mathematics and physics all from Kyoto University, Japan in 2002, 2004 and 2007, respectively. He is currently an assistant professor in the Department of Mechanical and Control Engineering, Tokyo Institute of Technology, Japan. His research interests include cooperative control and estimation for robotic networks and visual sensor networks. He received Outstanding Research Award and Best Paper Award from SICE in 2014 and 2009, respectively.


Host: Ashwin Dani, Ashwin.dani@engr.uconn.edu

ECE Seminar Series: Towards a formal design of distributed cooperative systems

ECE title

ECE Seminar Series Fall 2014

Thursday October 23st, 1-2 PM, ITEB 336

Towards a formal design of distributed cooperative systems

 Hai Lin

Assistant Professor, Electrical Engineering, University of Notre Dame


 Abstract: A common challenge in our future engineered system design, such as power grids, intelligent transportation networks and flexible-manufacturing systems, is how to make a large number of distributed systems work together in a reliable and efficient manner. Existing methods are either only suitable for small scale systematic synthesis, oversimplifying the nodal dynamics, or fail to adapt to changing environments. This motivates our research aiming at a scalable, correct-by-construction formal design methodology for distributed cooperative systems. In particular, we focus on a formal design of multi-robot systems that can guarantee the accomplishment of high-level team missions through automatic synthesis of local coordination mechanisms and control laws. The basic idea is to decompose the team mission into individual subtasks such that the design can be reduced to local synthesis problems for individual robots. Multidisciplinary approaches combining hybrid systems, supervisory control, inference deduction and model checking are utilized to achieve this goal. The developed theory will enable robots in the team to cooperatively learn their individual roles in a mission, and then automatically synthesize local supervisors to fulfill their subtasks. A salient feature of the proposed method lies on its ability to handle environmental uncertainties and un-modeled dynamics as we do not require an explicit model of the transition dynamics of each agent and their interactions with the environment. In addition, the design is on-line and reactive enabling the robot team to adapt to changing environments and dynamic tasking.


Short Bio: Hai Lin obtained his B.S. degree at the University of Science and Technology Beijing and his M.S. degree from the Chinese Academy of Sciences in 1997 and 2000 respectively. In 2005, he received his Ph.D. degree from the University of Notre Dame. Dr. Lin is currently an Assistant Professor at the Department of Electrical Engineering, University of Notre Dame. Before returning to his alma mater, Hai has been working as an assistant professor in the National University of Singapore from 2006 to 2011. Dr. Lin’s teaching and research interests are in the multidisciplinary study of the problems at the intersections of control, communication, computation and life sciences. His current research thrust is on cyber-physical systems, multi-robot cooperative tasking, systems biology and hybrid control. Hai has been served in several committees and editorial board. He is the Program Chair for IEEE ICCA 2011, IEEE CIS 2011 and the Chair for IEEE Systems, Man and Cybernetics Singapore Chapter for 2009 and 2010. He is a recipient of 2013 NSF CAREER award and a senior member of IEEE.


Host: Peng Zhang, peng@engr.uconn.edu

Special ECE/CSE Seminar: Challenges of Human-in-the-Loop Planning & Decision Support

ECE title

Special ECE/CSE Seminar

Tuesday October 21st 11 AM – 12 PM, ITEB 336

Challenges of Human-in-the-Loop Planning & Decision Support

Subbarao Kambhampati

Arizona State University

Abstract: Endowing  an automated agent with  the ability to “plan” — i.e., convert its high-level goals into an executable course of action — has been a long-standing quest in Artificial Intelligence.  For much of the history of automated planning, the dominant research theme has been efficient synthesis of plans under increasingly expressive system dynamics (classical, temporal, stochastic etc.).


An implicit assumption underlying  this research has been that the planner’s responsibilities start with taking a complete specification, and end with giving out a complete course of action. This assumption is no longer valid when humans are part of the decision making loop, as is the case in an increasing number of decision support and human-machine teaming scenarios.

In this talk I will identify the research challenges in human-in-the-loop planning, including the need to interpret the goals/intentions of the humans in the loop, the need to support continual planning and replanning, the need to unobtrusively support team-decision making, and above all the need to do handle pervasive incompleteness in the domain models as well as problem specification.  I will then describe some of our ongoing work in handling these challenges in the context of human-robot teaming and crowd-sourced planning.


Short Bio: Dr. Subbarao Kambhampati is a professor of Computer Science at Arizona State University, where he leads the Yochan research group focusing on the challenges in  automated planning and decision support, as well as information integration from structured and unstructured data sources.  He is a 1994 NSF Young Investigator, a 2004 IBM faculty fellow and thrice received Google Research Awards. He was elected fellow of AAAI (in 2004) for his contributions to automated planning. He received the 2002 college of engineering teaching excellence award, 2011 university last lecture invitation, and 2012 departmental best teacher award. Kambhampati was the co-chair of AAAI 2005, and will be the program chair of IJCAI 2016. He is an elected Trustee of IJCAI, and the president-elect of AAAI.


Host: Krishna Pattipati, krishna@engr.uconn.edu